Human-Robot Collaborative Operating System
Connecting personnel, intelligent perception, and robotic operations to ensure the orderly execution of on-site tasks while making operational outcomes traceable and verifiable.
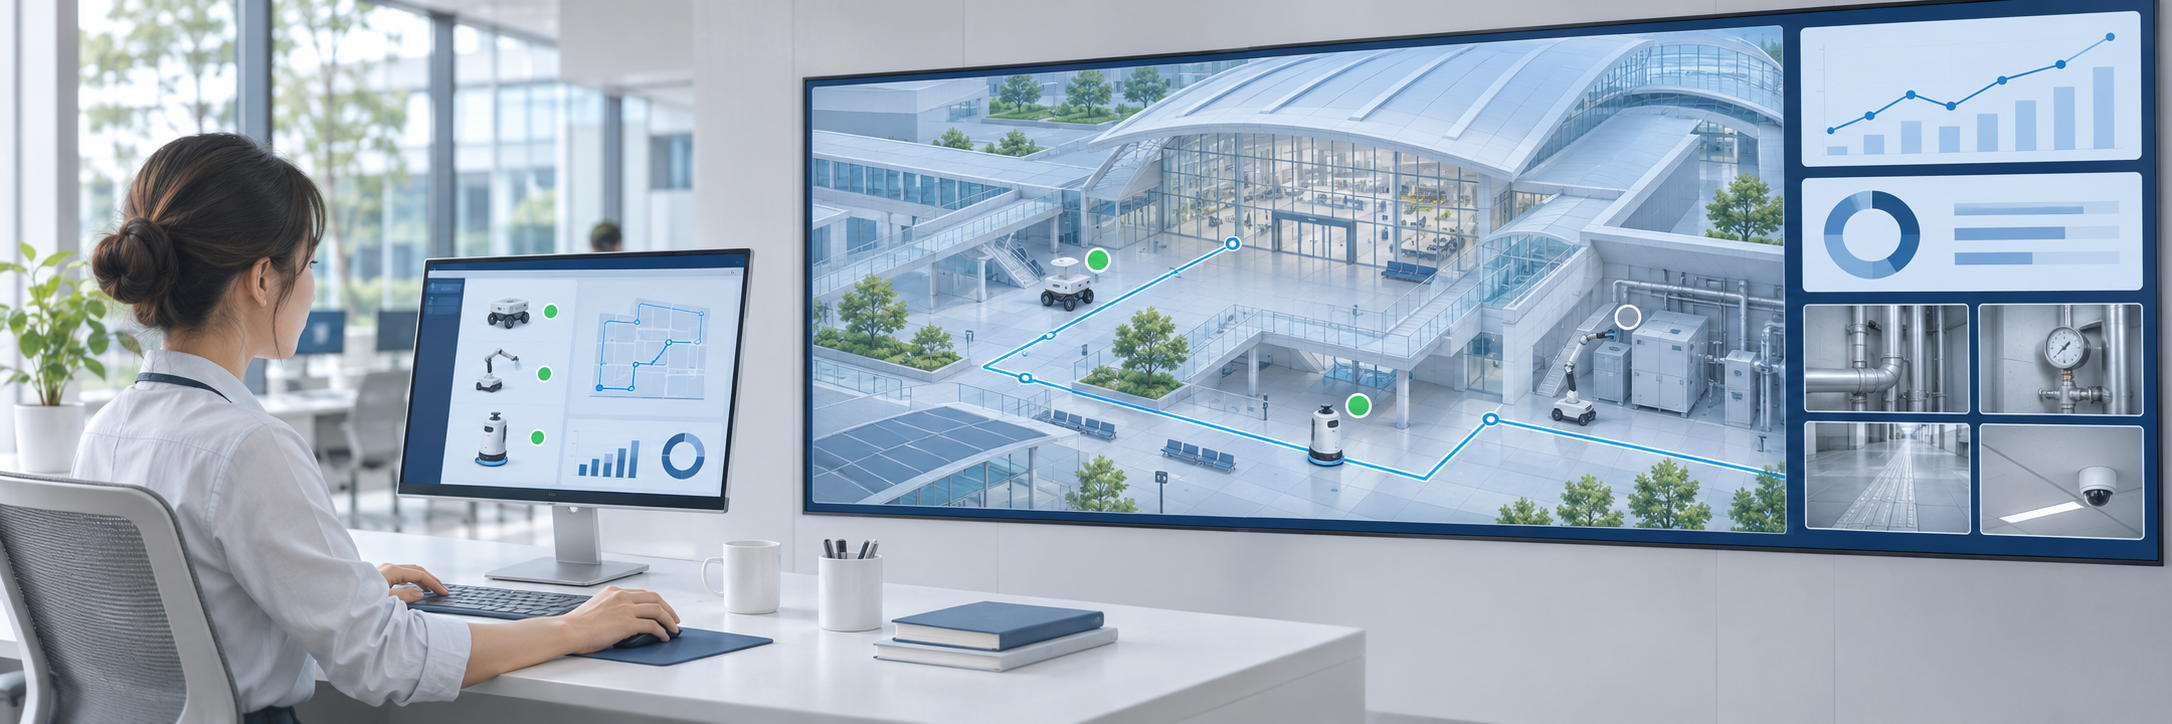
Human oversight, platform orchestration, and field execution
Connecting personnel, field equipment, and client business systems via the management platform to form a closed loop of task execution, data return, verification and resolution, and result archiving.
Human decision-making and oversight
Formulate operational requirements
Targets · Standards · Frequency · Thresholds
Define roles and permissions
Management · Dispatch · Verification · Maintenance
Authorize critical decisions
Exception Verification · Resolution Decision · Acceptance
Platform orchestration and dispatch
Tasks and dispatch
Allocate terminals according to operational plans, and schedule routes, task points, and actions.
Space and assets
Link maps, routes, waypoints, and assets to locate tasks and evidence.
Data and quality
Aggregate imagery, point clouds, and sensor data to preserve field evidence.
Operations and collaboration
Monitor equipment status, task progress, and alerts to coordinate operations.
Anomalies and work orders
Link anomalies, responsibilities, and work orders to track responses and re-testing.
Reporting and Archiving
Summarize task results and resolution logs to generate traceable reports.
On-site execution and perception
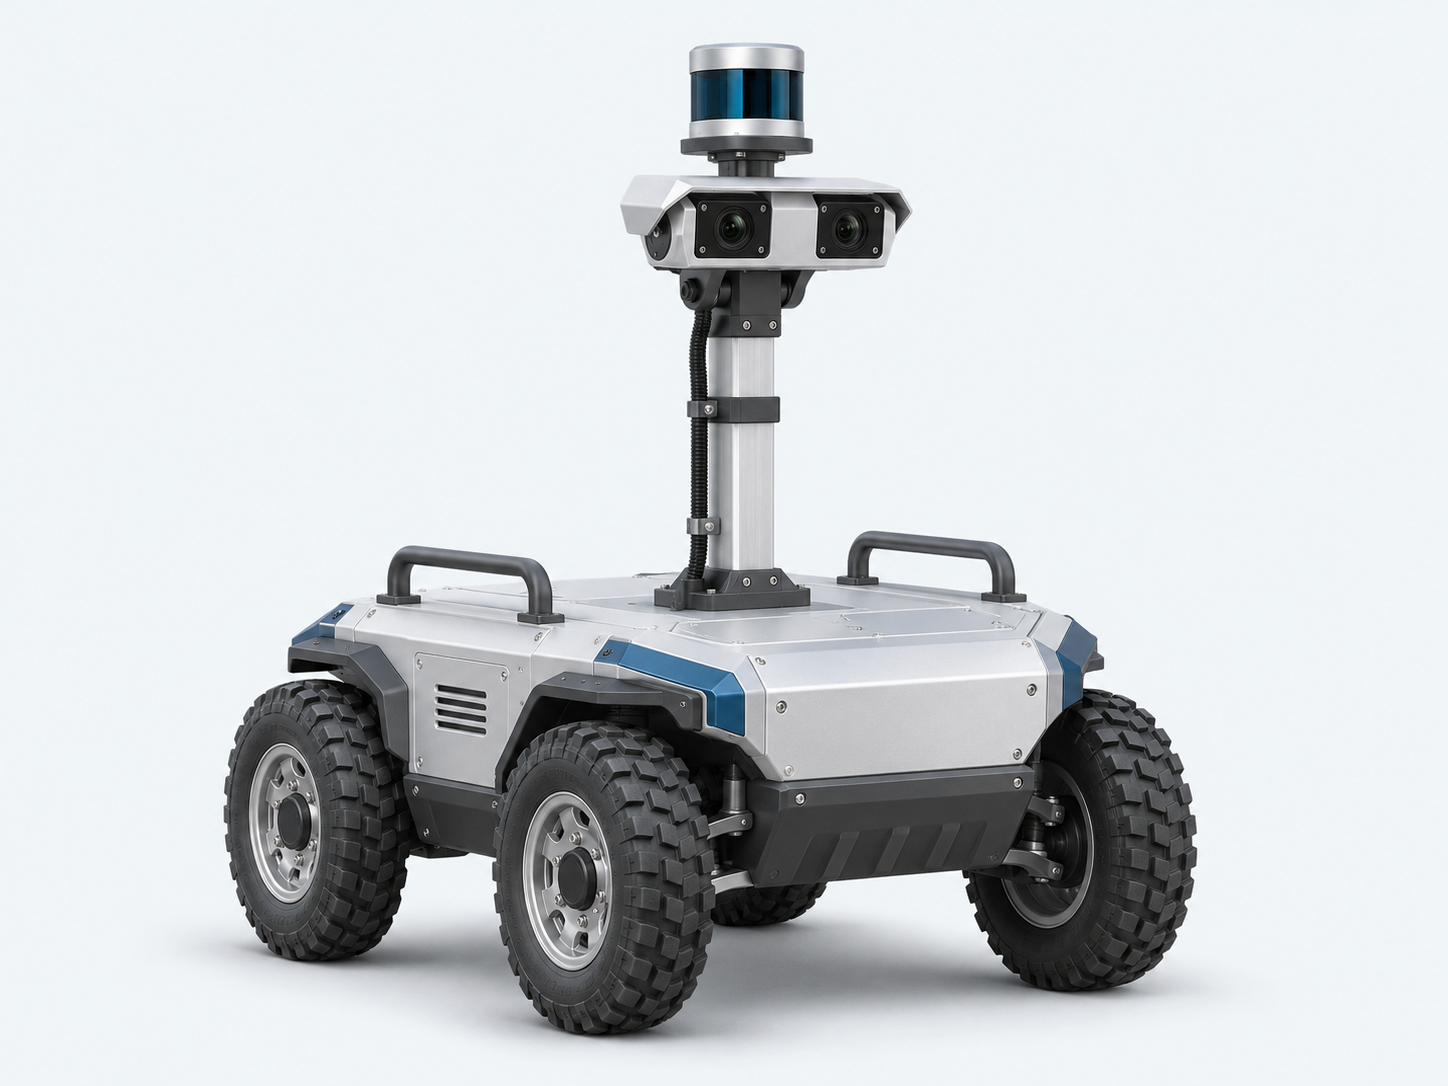
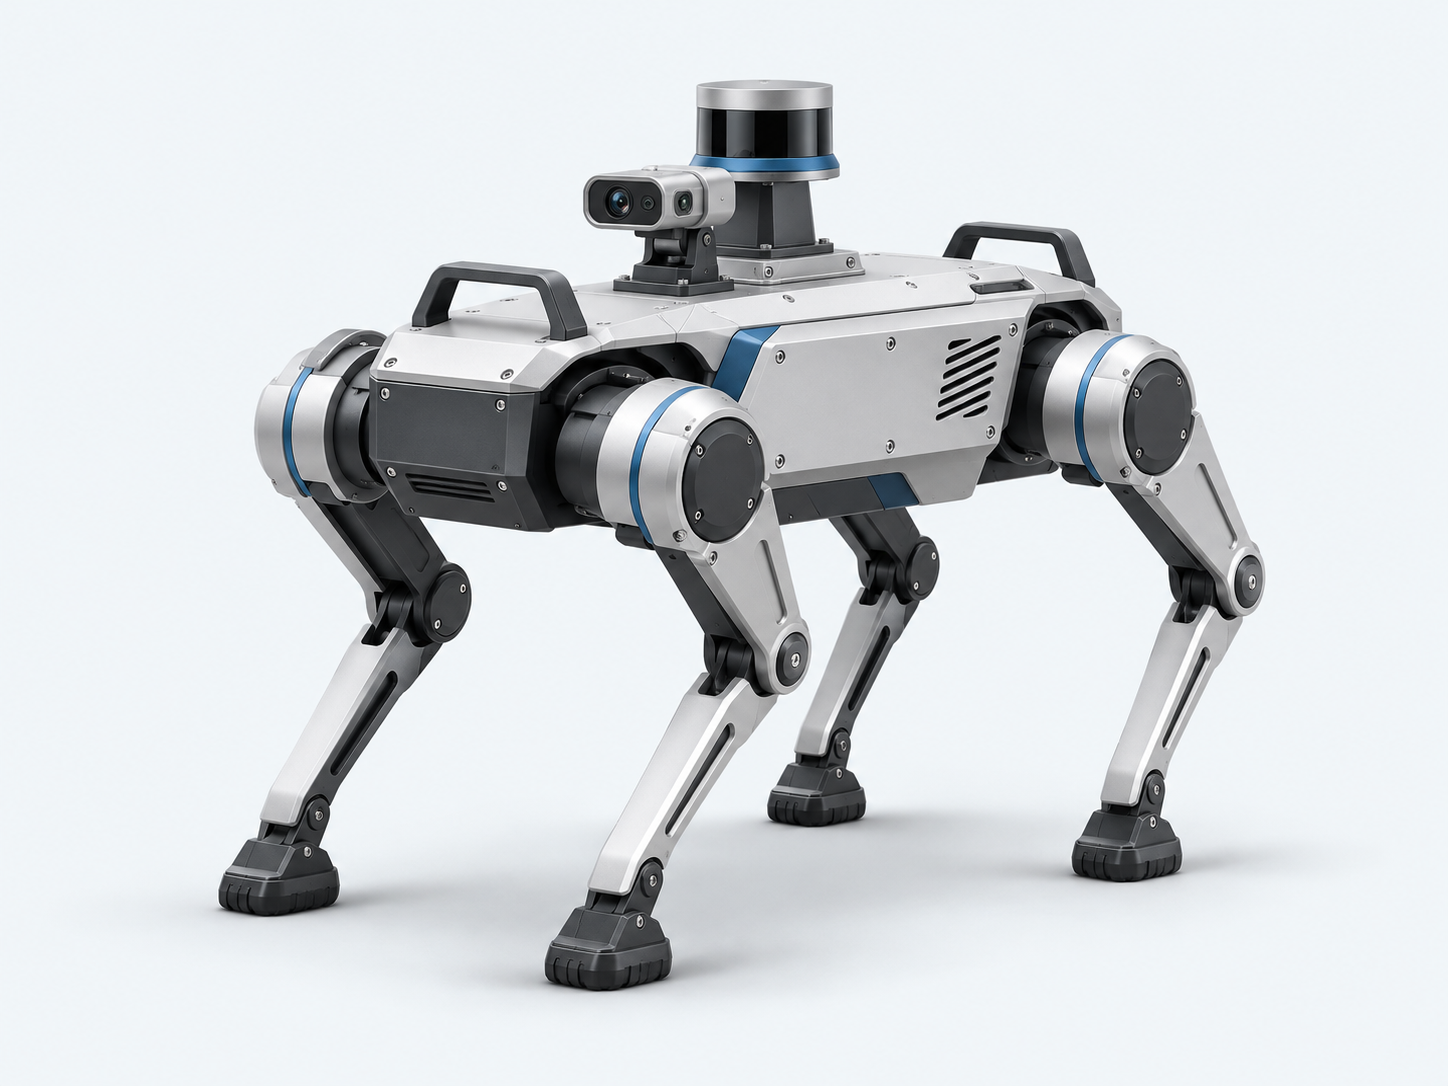
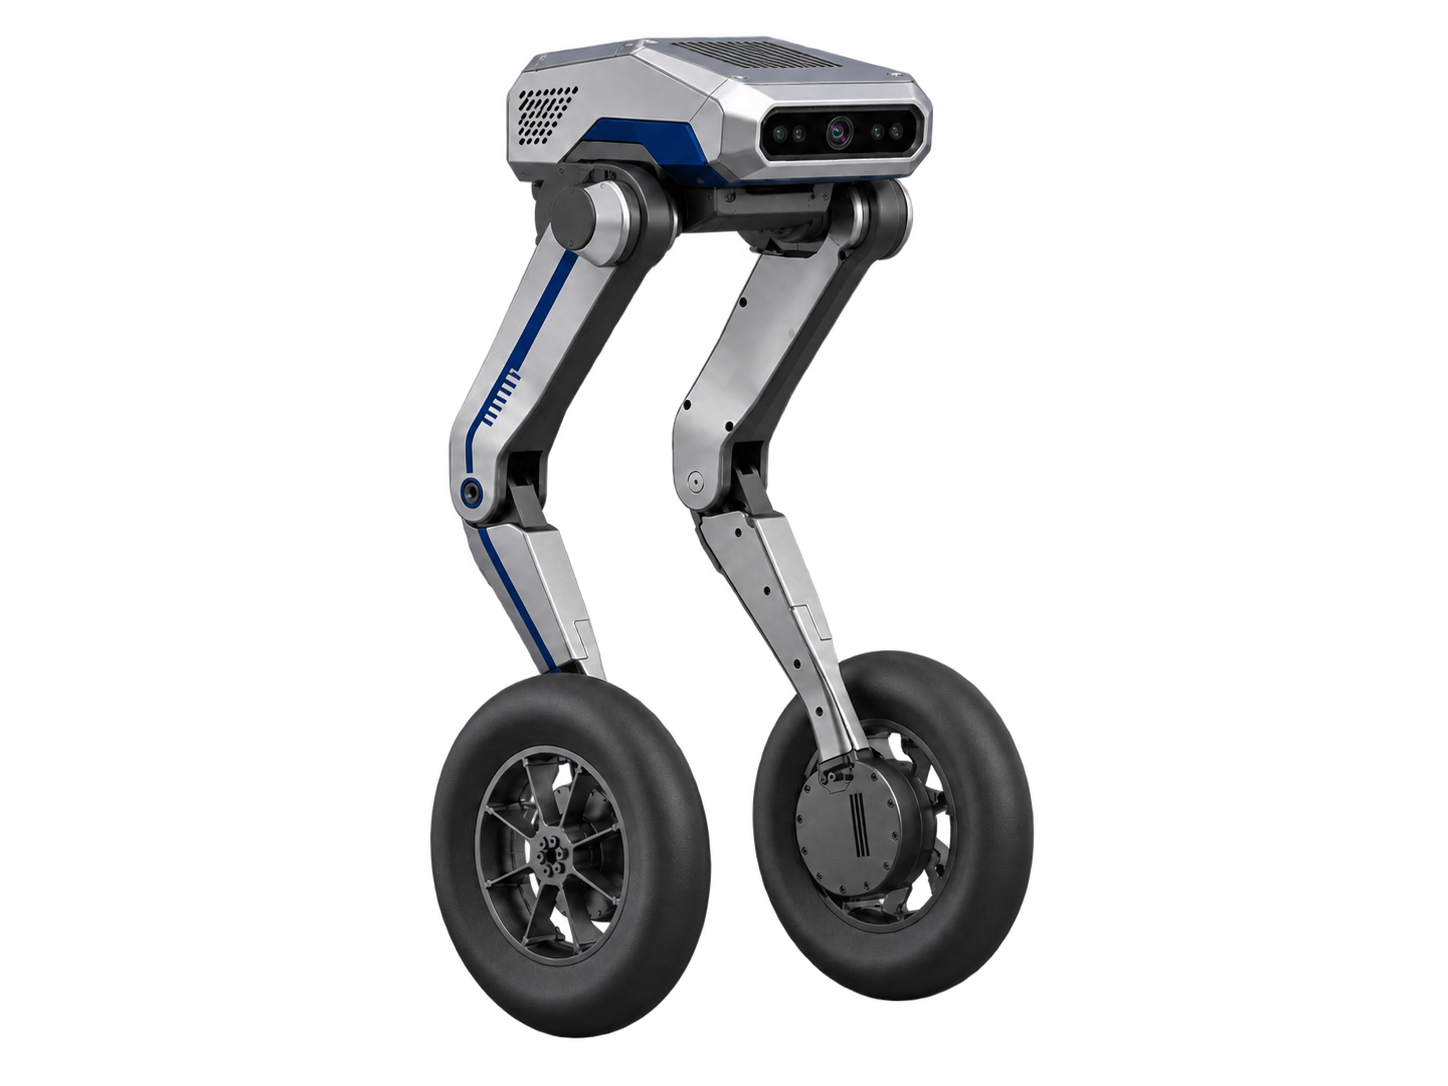
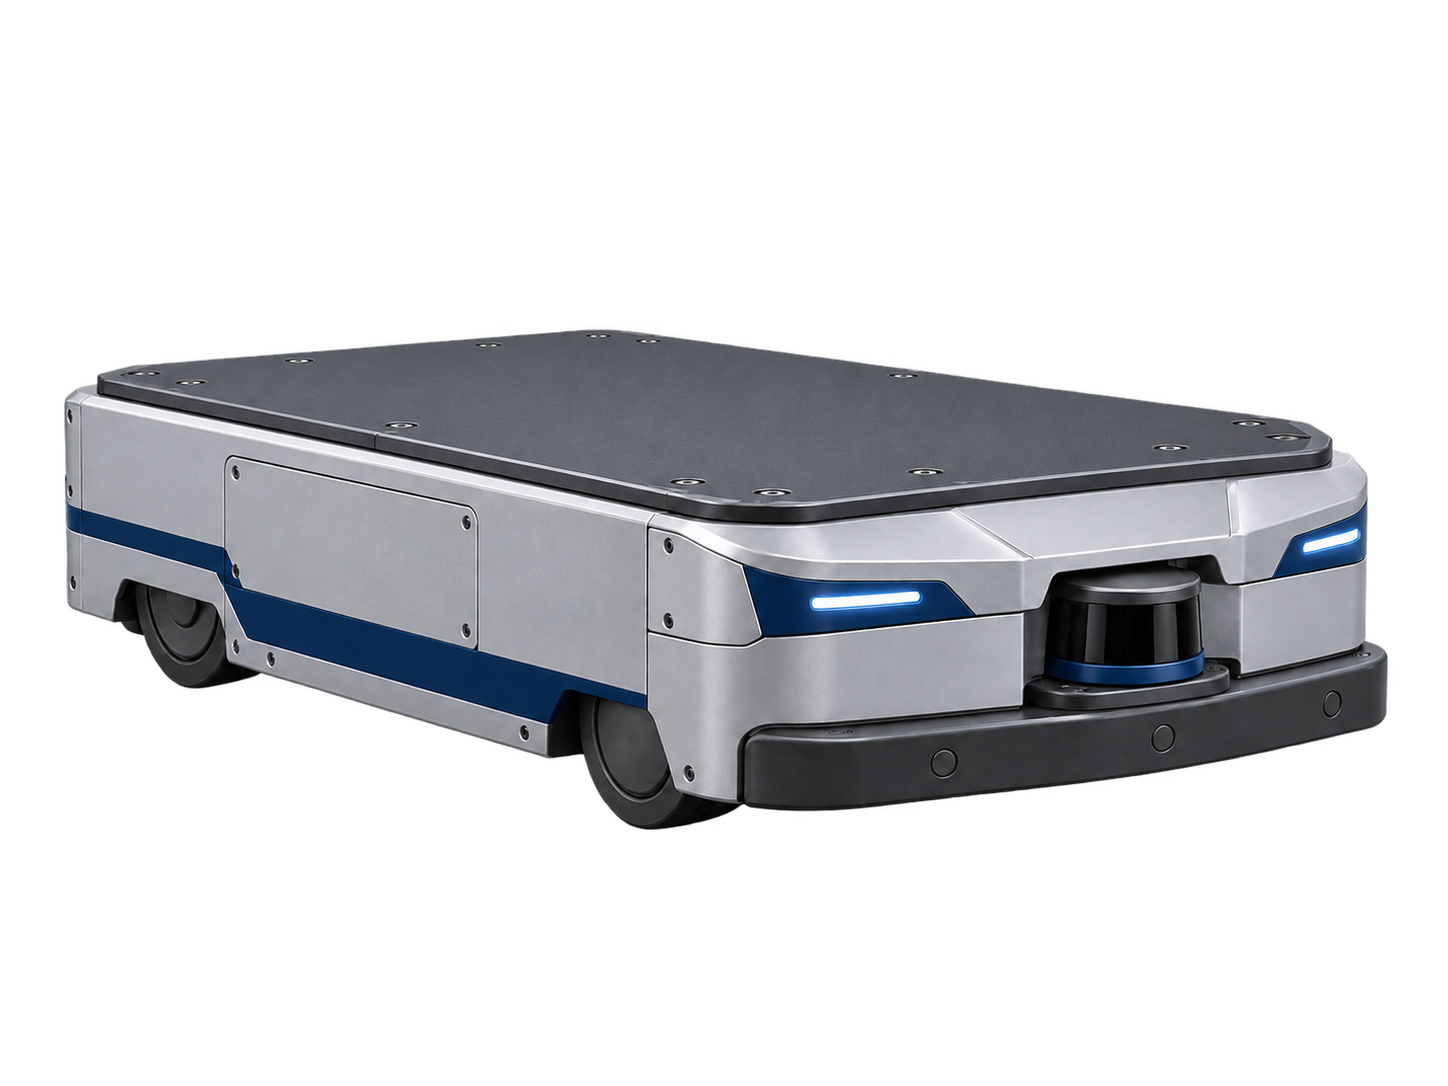
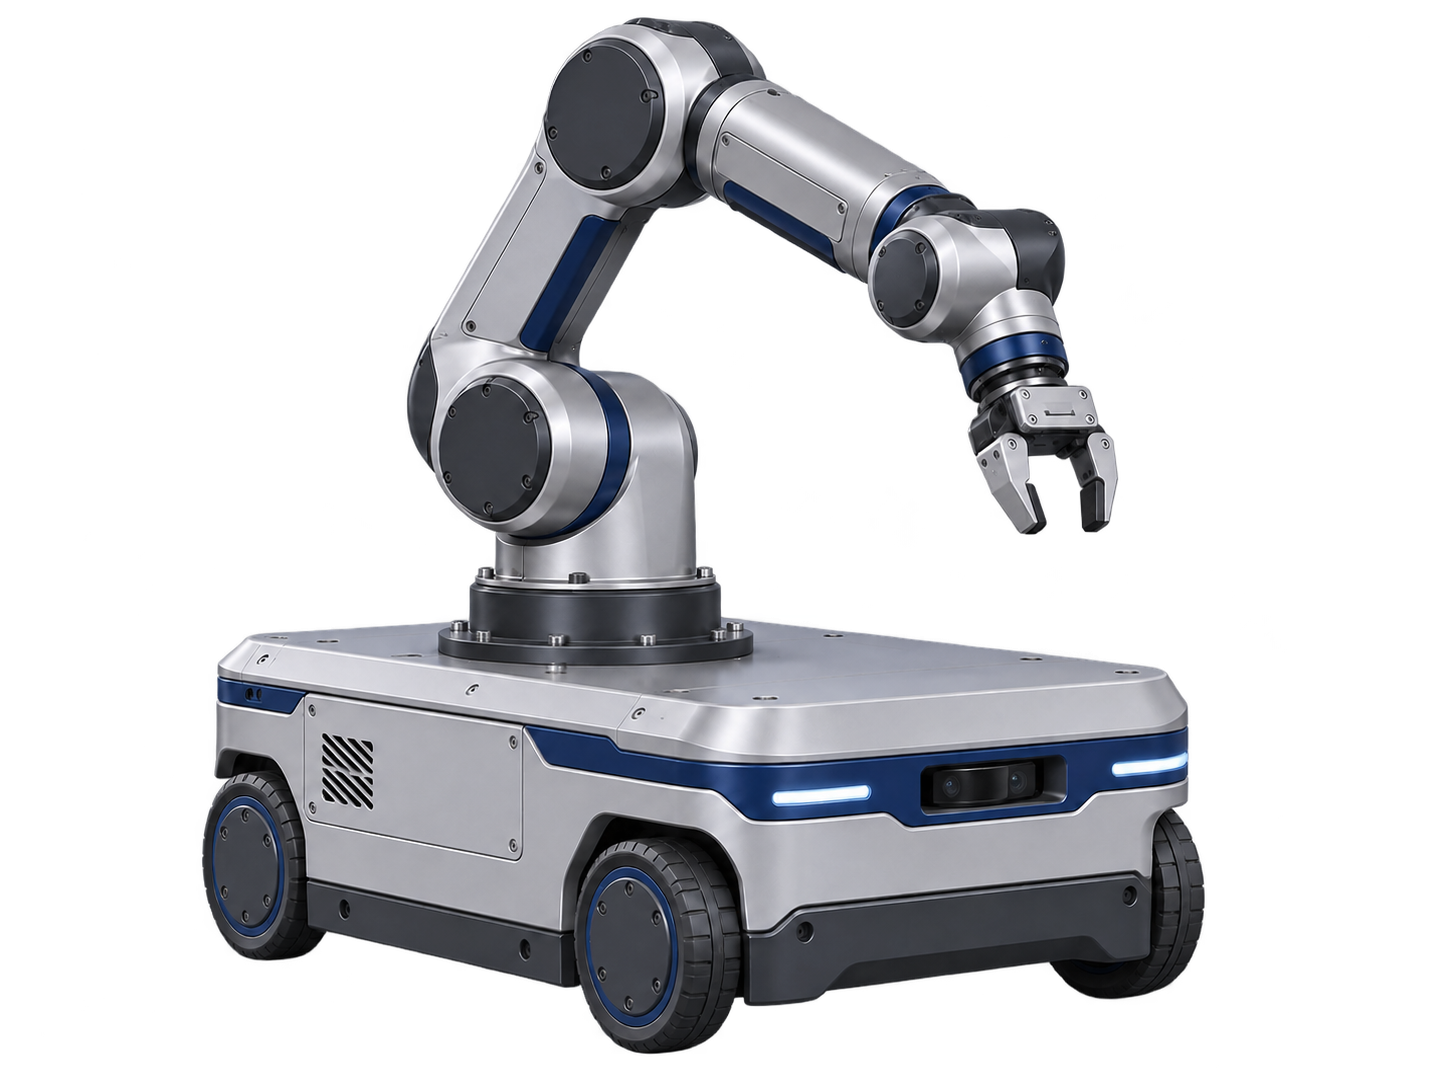
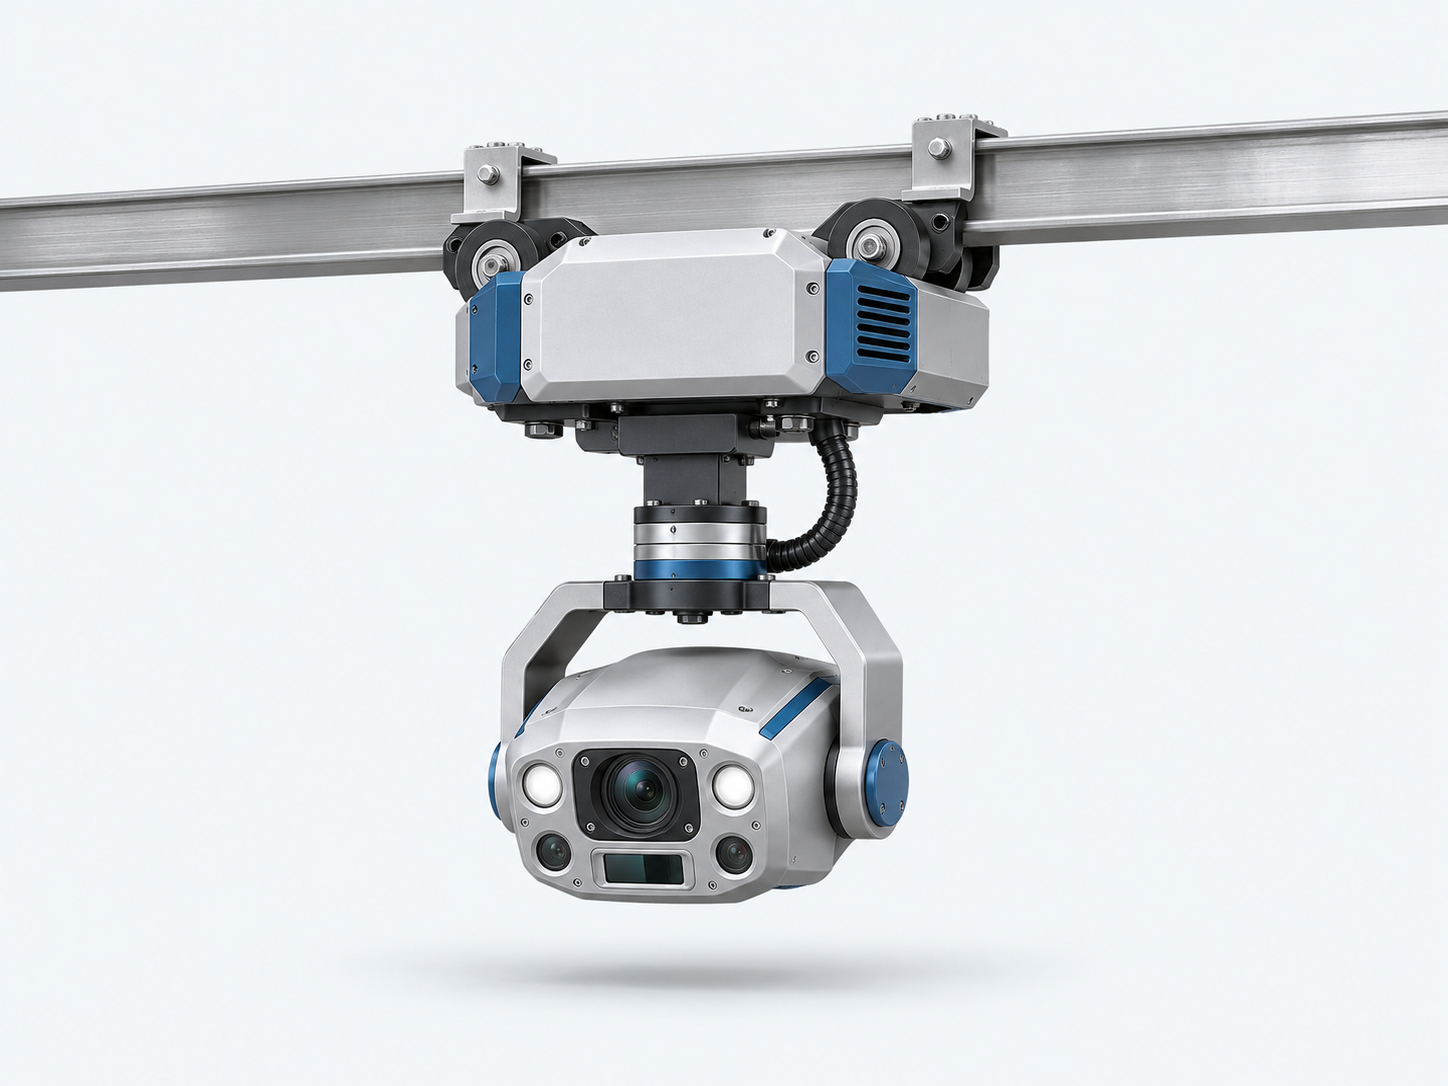
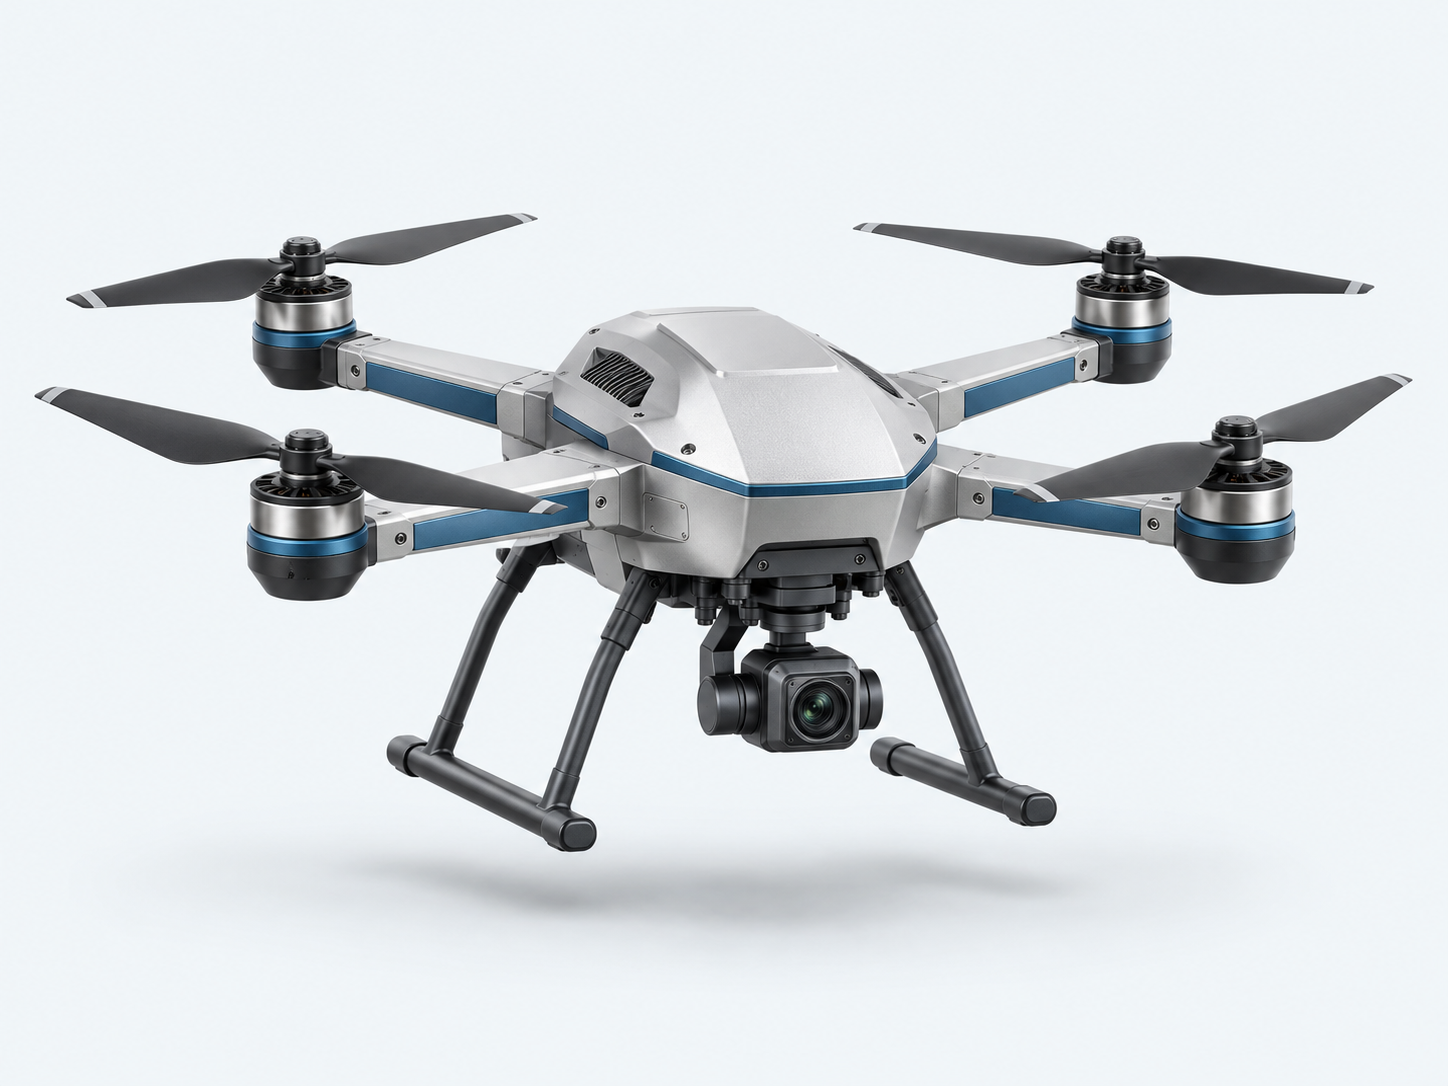
Schematic diagram of robotic terminal forms · Equipment and capabilities adapted to project requirements
System data
Field records · Task results · Reports
Customer's existing systems
- Asset Management
- Operations and Maintenance Management
- Work Order System
- ERP
- BIM / CIM
- SCADA / IoT
- Security and Access Control
- Messaging Platform
Applications & Expansion
A unified core architecture supporting the expansion of operational modules based on on-site requirements.
Learn how this system can be applied to your operations.